QSPI
This document describes QSPI functionality and usage.
Overview
QSPI (Quad SPI) is a serial interface bus between the SoC and peripheral devices that supports x4 mode. SPI supports both master and slave modes. Typically, one master device is connected to one or more slave devices. The master selects the target slave for communication, provides the clock, and initiates all read and write operations. K3 QSPI currently supports master mode only.
Functionality
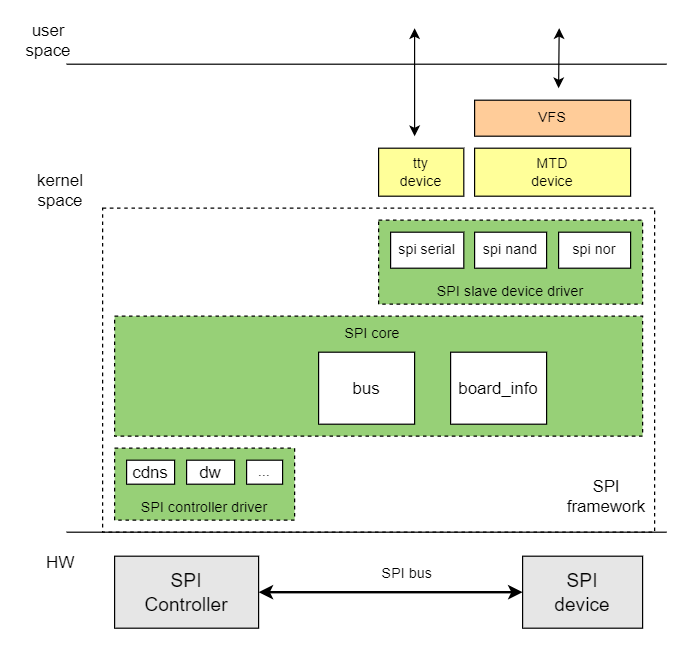
The Linux SPI driver framework is divided into three parts: SPI core, SPI controller driver, and SPI device driver. SPI core mainly provides the following functions:
- Registers SPI buses and
spi_masterclasses - Adds and removes SPI controllers
- Adds and removes SPI devices
- Registers and unregisters SPI device drivers
SPI controller driver:
- The SPI master controller driver, which operates the SPI master controller
SPI device driver:
- The SPI device driver
Source Code Structure
The controller driver code is located in the drivers/spi directory:
|-- spi-fsl-qspi.c #k3 qspi driver
Key Features
Feature
| Feature | Description |
|---|---|
| Communication Protocol | Supports SSP/SPI/MicroWire/PSP protocols |
| Communication Frequency | Supports a maximum frequency of 102MHz and a minimum frequency of 30MHz |
| Communication Multiplier | x1/x2/x4 |
| Supported Peripherals | Supports spi-nor and spi-nand |
Performance Parameters
Communication Frequency
The current QSPI controller supports up to 102MHz. The list of supported communication frequencies is as follows:
- 30.72MHz
- 35.10MHz
- 40.96MHz
- 53.57MHz
- 68.26MHz
- 75MHz
- 81.92MHz
- 93.75MHz
- 98.3MHz
- 102.4MHz
Communication Multiplier
QSPI supports communication multipliers of x1/x2/x4.
Testing method: Use an oscilloscope or logic analyzer to measure the SCK frequency and confirm the communication multiplier.
Configuration
Configuration mainly includes driver enablement and DTS settings.
Kconfig Configuration
CONFIG_SPI: Provides support for the SPI bus protocol. The default value isY.
Device Drivers
        SPI support (SPI [=y])
CONFIG_SPI_MEM: Provides support for simplified operations on SPI memory devices. The default value isY.
Device Drivers
        SPI support (SPI [=y])
                SPI memory extension (SPI_MEM [=y])
CONFIG_SPI_FSL_QUADSPI: Provides support for the K3 QSPI controller driver. The default value isY.
Device Drivers
        SPI support (SPI [=y])
                Freescale QSPI controller (SPI_FSL_QUADSPI [=y])
DTS Configuration
pinctrl
Check the board schematic to determine which pin group is used by QSPI. You can refer to the Pin Configuration Definitions section in PINCTRL to identify the QSPI pin group.
Assuming QSPI can directly use the pinctrl_qspi group defined in k3-x_pinctrl.dtsi.
SPI Device Configuration
You need to confirm the SPI device type, as well as the communication frequency and multiplier used between QSPI and the SPI device.
Device Type
Confirm whether the SPI device connected to QSPI is spi-nor or spi-nand.
Communication Frequency
Confirm the maximum communication rate supported by both the QSPI controller and the SPI device. The list of communication frequencies supported by the current QSPI controller is given in Performance Parameters > Communication Frequency in this document.
SPI Device DTS
Taking SPI NOR as an example, use a maximum communication frequency of 30MHz, with both transmit and receive operating in x4 mode.
// Specify the voltage required by the pins here. 1.8V is used as an example. For more details, refer to the pinctrl chapter.
&pinctrl {
    qspi-cfg {
        qspi-0-pins {
            power-source = <1800>;
        };

        qspi-1-pins {
            power-source = <1800>;
        };
    };
};

&qspi {
    pinctrl-names = "default";
    pinctrl-0 = <&qspi_cfg>;
    status = "okay";

    flash@0 {
        compatible = "jedec,spi-nor";
        reg = <0>;
        spi-max-frequency = <30000000>;
        m25p,fast-read;
        spi-tx-bus-width = <4>;
        spi-rx-bus-width = <4>;
        broken-flash-reset;
        status = "okay";
    };
};
DTS Example
SPI-NOR
Based on the above information, QSPI is connected to SPI-NOR flash with a maximum communication frequency of 30MHz and x4 communication.
Example DTS configuration:
&pinctrl {
    qspi-cfg {
        qspi-0-pins {
            power-source = <1800>;
        };

        qspi-1-pins {
            power-source = <1800>;
        };
    };
};

&qspi {
    pinctrl-names = "default";
    pinctrl-0 = <&qspi_cfg>;
    status = "okay";

    flash@0 {
        compatible = "jedec,spi-nor";
        reg = <0>;
        spi-max-frequency = <30000000>;
        m25p,fast-read;
        spi-tx-bus-width = <4>;
        spi-rx-bus-width = <4>;
        broken-flash-reset;
        status = "okay";
    };
};
SPI-NAND
QSPI is connected to SPI-NAND flash with a maximum communication frequency of 30MHz and x4 communication.
The board-level DTS configuration can refer to the SPI-NOR example; only the flash device node needs to be modified.
&pinctrl {
    qspi-cfg {
        qspi-0-pins {
            power-source = <1800>;
        };

        qspi-1-pins {
            power-source = <1800>;
        };
    };
};

&qspi {
    pinctrl-names = "default";
    pinctrl-0 = <&qspi_cfg>;
    status = "okay";

    flash@0 {
        compatible = "spi-nand";
        reg = <0>;
        spi-max-frequency = <30000000>;
        m25p,fast-read;
        spi-tx-bus-width = <4>;
        spi-rx-bus-width = <4>;
        broken-flash-reset;
        status = "okay";
    };
};
Interface
API
Device driver registration and unregistration:
int __spi_register_driver(struct module *owner, struct spi_driver *sdrv);
void spi_unregister_driver(struct spi_driver *sdrv);
Data transfer APIs:
- Initialize
spi_message
void spi_message_init(struct spi_message *m);
- Add
spi_transferto the transfer list ofspi_message
void spi_message_add_tail(struct spi_transfer *t, struct spi_message *m);
- Write data
int spi_write(struct spi_device *spi, const void *buf, size_t len);
- Read data
int spi_read(struct spi_device *spi, void *buf, size_t len);
- Synchronously transfer
spi_message
int spi_sync(struct spi_device *spi, struct spi_message *message);
Debugging
sysfs
View SPI bus device and driver information in the system:
/sys/bus/spi
|-- devices                 // Devices on the SPI bus
|-- drivers                 // Drivers registered on the SPI bus
|-- drivers_autoprobe
|-- drivers_probe
`-- uevent
debugfs
Used to view SPI device information in the system:
/sys/kernel/debug/spi-nor/spi4.0
|-- capabilities
`-- params

# cat capabilities
Supported read modes by the flash
 1S-1S-1S
  opcode        0x03
  mode cycles   0
  dummy cycles  0
 1S-1S-1S (fast read)
  opcode        0x0b
  mode cycles   0
  dummy cycles  8
 1S-1S-2S
  opcode        0x3b
  mode cycles   0
  dummy cycles  8
 1S-2S-2S
  opcode        0xbb
  mode cycles   2
  dummy cycles  2
 1S-1S-4S
  opcode        0x6b
  mode cycles   0
  dummy cycles  8
 1S-4S-4S
  opcode        0xeb
  mode cycles   2
  dummy cycles  4
 4S-4S-4S
  opcode        0xeb
  mode cycles   2
  dummy cycles  2

Supported page program modes by the flash
 1S-1S-1S
  opcode        0x02

# cat params
name            gd25lq64c
id              c8 60 17 c8 60 17
size            8.00 MiB
write size      1
page size       256
address nbytes  3
flags           HAS_SR_TB | BROKEN_RESET | HAS_LOCK | HAS_16BIT_SR | NO_READ_CR | SOFT_RESET

opcodes
 read           0xeb
  dummy cycles  6
 erase          0x20
 program        0x02
 8D extension   none

protocols
 read           1S-4S-4S
 write          1S-1S-1S
 register       1S-1S-1S

erase commands
 20 (4.00 KiB) [1]
 52 (32.0 KiB) [2]
 d8 (64.0 KiB) [3]
 c7 (8.00 MiB)

sector map
 region (in hex)   | erase mask | overlaid
 ------------------+------------+----------
 00000000-007fffff |     [ 1  ] | no
Testing
SPI-NAND/NOR Read/Write Speed Test
Enable CONFIG_MTD_TESTS
Device Drivers
         Memory Technology Device (MTD) support (MTD [=y])
                MTD tests support (DANGEROUS) (MTD_TESTS [=m])
Test command:
insmod mtd_speedtest.ko dev=0 # 0 indicates the MTD device number of SPI-NAND/NOR