2.4 Python Usage Guide
This guide covers the essentials of using Python on the Bianbu ROS system.
Common Commands Summary
| Function | Command |
|---|---|
| Install virtual environment tools | sudo apt install python3-venv python3-pip |
| Create virtual environment | python3 -m venv myenv |
| Activate virtual environment | source myenv/bin/activate |
| Upgrade pip | pip install --upgrade pip |
| Set PyPI source | pip config set global.index-url https://pypi.tuna.tsinghua.edu.cn/simplepip config set global.extra-index-url https://git.spacemit.com/api/v4/projects/33/packages/pypi/simple |
| Deactivate virtual environment | deactivate |
Using Python in the System Environment
The Bianbu ROS system includes a default Python interpreter. You can access it by typing python3 in the terminal:
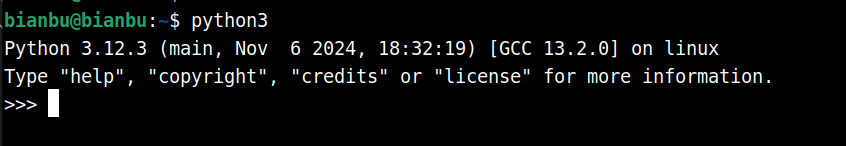
Exit the interpreter with Ctrl + D.
-
Check Python Location Use
which python3to find the Python interpreter’s path:bianbu@bianbu:~$ which python3# Output example/usr/bin/python3 -
Install Packages in the System Environment Use
apt(notpip) to manage Python packages in the system environment. For example, to install the scientific computing libraryscipy:sudo apt install python3-scipyTo find available Python packages, use:
apt search python3-Example: The
numpypackage is listed aspython3-numpy.Note: Do not use
pipto install packages in the system environment to avoid conflicts.
Using a Virtual Environment
To use a virtual environment, create an isolated environment to hold your Python packages. There are several ways to do this, depending on how you plan to use Python. Here, we use the venv tool as an example.
-
Install
venvin the system Python environment:sudo apt install python3-venv python3-pip -
Run the following command to create a folder for your virtual environment (replace
myenvwith any name you prefer):python3 -m venv myenv -
Execute the
bin/activatescript inside the virtual environment folder to enter the virtual environment:source myenv/bin/activateYour terminal prompt changes to indicate the active environment:
(myenv) ➜ ~The
myenvprefix in the command prompt indicates that the current terminal session is inside the virtual environment namedmyenv. -
To verify the virtual environment, use
pip listto view the list of installed packages:(myenv) ➜ ~ pip listPackage Version------- -------pip 24.0The list should be shorter than the list of packages installed in the system Python environment.
-
You can now safely install Python packages using
pip. Here are the key points to remember:-
Packages installed with
pipwill exist only in your current virtual environment. Your system-wide Python environment will not be affected. -
When your virtual environment is activated:
- The
pythonandpython3commands will automatically use the virtual environment's interpreter - All imported packages will come from the virtual environment, not the system
- The
To ensure proper use of
pip, upgrade it to the latest version:pip install --upgrade pipExample: install the
wheelpackage using pip:(myenv) ➜ ~ pip install wheelCollecting wheelDownloading wheel-0.44.0-py3-none-any.whl.metadata (2.3 kB)Downloading wheel-0.44.0-py3-none-any.whl (67 kB)━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━ 67.1/67.1 kB 27.9 kB/s eta 0:00:00Installing collected packages: wheelSuccessfully installed wheel-0.44.0Verify installation in Python by running
python3and then importing the installed module:(myenv) ➜ ~ python3Python 3.12.3 (main, Apr 10 2024, 05:33:47) [GCC 13.2.0] on linuxType "help", "copyright", "credits" or "license" for more information.>>> import wheel -
-
Verify the interpreter path by using the
sysmodule to check that the current interpreter path matches the expected virtual environment:>>> import sys>>> print("Current Python interpreter path:", sys.executable)Current Python interpreter path: /home/zq-card/myenv/bin/python3 -
Use
exit()to quit the interactive mode:>>> exit()(myenv) ➜ ~ -
To exit the virtual environment, run the following command:
(myenv) ➜ ~ deactivate
Configuring SpacemiT PyPI Source
When installing Python packages in a virtual environment using pip, you may encounter the following issue on RISC-V platforms:
- If no precompiled
.whl(wheel) file is available,pipwill download the source code and try to build it locally. - Packages that include C/C++ code can take a long time to compile and may fail if system dependencies are missing.
To improve efficiency and avoid build errors, SpacemiT provides precompiled wheel files for common Python packages such as numpy.
This section explains how to configure pip to use SpacemiT’s package source.
-
Configure as an extra source
By default,
pipsupports one mainindex-url(the main package source). You can add an additional source usingextra-index-url.Run the following commands to add the SpacemiT source as an additional location to search for packages:
pip config set global.index-url https://pypi.tuna.tsinghua.edu.cn/simplepip config set global.extra-index-url https://git.spacemit.com/api/v4/projects/33/packages/pypi/simpleYou can verify the configuration with:
pip config listIf successful, you will see output similar to:
global.extra-index-url='https://git.spacemit.com/api/v4/projects/33/packages/pypi/simple'global.index-url='https://pypi.tuna.tsinghua.edu.cn/simple' -
Install PyPI Packages
To install a package from the SpacemiT source, use the following command:
pip install --index-url https://git.spacemit.com/api/v4/projects/33/packages/pypi/simple <package_name>Replace
<package_name>with the desired package.
Using ONNX Runtime
Please make sure you have completed the previous sections before proceeding.
This section explains how to set up onnxruntime with SpacemiT’s custom execution provider (spacemit_ort), verify the installation, and run a sample inference demo.
-
Create a Virtual Environment
python3 -m venv ort_envActivate it:
source ort_env/bin/activate -
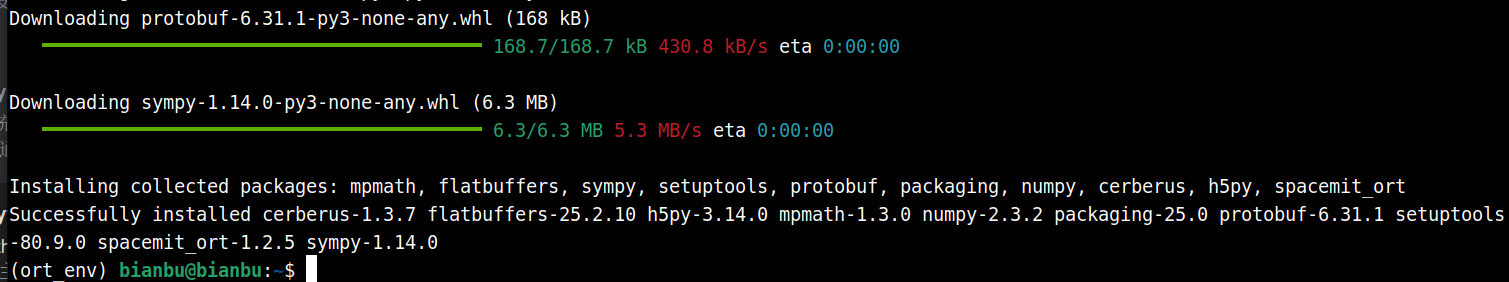
Install
spacemit_ortpip install spacemit_ortIf successful, the terminal will show an installation summary similar to this:
-
Verify the Installation
-
Launch Python inside the virtual environment with the following commands:
python>>> import onnxruntime as ort>>> import spacemit_ort>>> available_providers = ort.get_available_providers()>>> print(available_providers)['SpaceMITExecutionProvider', 'CPUExecutionProvider']If everything is installed correctly, the output should include:
['SpaceMITExecutionProvider', 'CPUExecutionProvider'] -
Exit Python with
Ctrl + D.
-
-
Installing Demo Dependencies
source ort_env/bin/activatepip install opencv-python pillow matplotlib onnx -
Download Models, Labels, and Images
SpacemiT provides quantized open-source models, which can be downloaded from ModelZoo.
In theory, ONNX models can also be used for inference, but their performance may be slightly lower than our quantized versions.
Download and extract the model and related files:
wget https://archive.spacemit.com/spacemit-ai/ModelZoo/classification.tar.gztar -zxf classification.tar.gzwget -P classification https://archive.spacemit.com/spacemit-ai/ModelZoo/classification/kitten.jpgwget -P classification https://archive.spacemit.com/spacemit-ai/ModelZoo/classification/synset.txt -
Run the Demo Script
- Create a file called
demo.py:
vim demo.py- Paste the following code into it:
import onnximport numpy as npimport onnxruntime as ortimport spacemit_ortfrom PIL import Imageimport cv2import matplotlib.pyplot as pltimport time# Image loadingdef get_image(path, show=False):with Image.open(path) as img:img = np.array(img.convert('RGB'))if show:plt.imshow(img)plt.axis('off')return img# Image Preprocessing# Preprocess the input image for inference -> scale to 0~1, resize to 256x256, take a 224x224 center crop, normalize the image, transpose to NCHW format, convert to float32, and add a batch dimension.def preprocess(img):img = img / 255.img = cv2.resize(img, (256, 256))h, w = img.shape[0], img.shape[1]y0 = (h - 224) // 2x0 = (w - 224) // 2img = img[y0 : y0+224, x0 : x0+224, :]img = (img - [0.485, 0.456, 0.406]) / [0.229, 0.224, 0.225]img = np.transpose(img, axes=[2, 0, 1])img = img.astype(np.float32)img = np.expand_dims(img, axis=0)return img# Predictiondef predict(path):img = get_image(path, show=True)img = preprocess(img)ort_inputs = {session.get_inputs()[0].name: img}start = time.time()preds = session.run(None, ort_inputs)[0]end = time.time()preds = np.squeeze(preds)a = np.argsort(preds)[::-1]print('time=%.2fms; class=%s; probability=%f' % (round((end-start) * 1000, 2), labels[a[0]], preds[a[0]]))# Load model, labels, and run inferencewith open('classification/synset.txt', 'r') as f:labels = [l.rstrip() for l in f]# Set the number of inference threadssession_options = ort.SessionOptions()session_options.intra_op_num_threads = 2# IMPORTANT: Specified SpaceMITExecutionProvider providerssession = ort.InferenceSession('classification/resnet50/resnet50.q.onnx', sess_options=session_options, providers=["SpaceMITExecutionProvider"])img_path = 'classification/kitten.jpg'predict(img_path) - Create a file called
-
Run the Demo
source ort_env/bin/activatepython demo.pyExpected output (your numbers may vary slightly):
time=95.15ms; class=n02123045 tabby, tabby cat; probability=13.498201
API Reference
For more information about available APIs, see the official API Overview.
Using gpiozero
The Python gpiozero library can be used to control the GPIO pins on the board, enabling basic input/output, PWM, and other functions.
-
Install system dependencies
Run this command to install
gpiozerowith the necessary system permissions for GPIO access:sudo apt install python3-gpiozero -
Install inside Virtual Environment
# Create a virtual environment named gpioenvpython3 -m venv gpioenv# Activate the environmentsource gpioenv/bin/activate# Install gpiozero using the SpacemiT package sourcepip install gpiozero --index-url https://git.spacemit.com/api/v4/projects/33/packages/pypi/simpleFor a detailed usage guide, see the official section Using GPIO from Python.